01 / AUTONOMOUS NAVIGATION / SIMULATION
Cruise navigation without GNSS updates
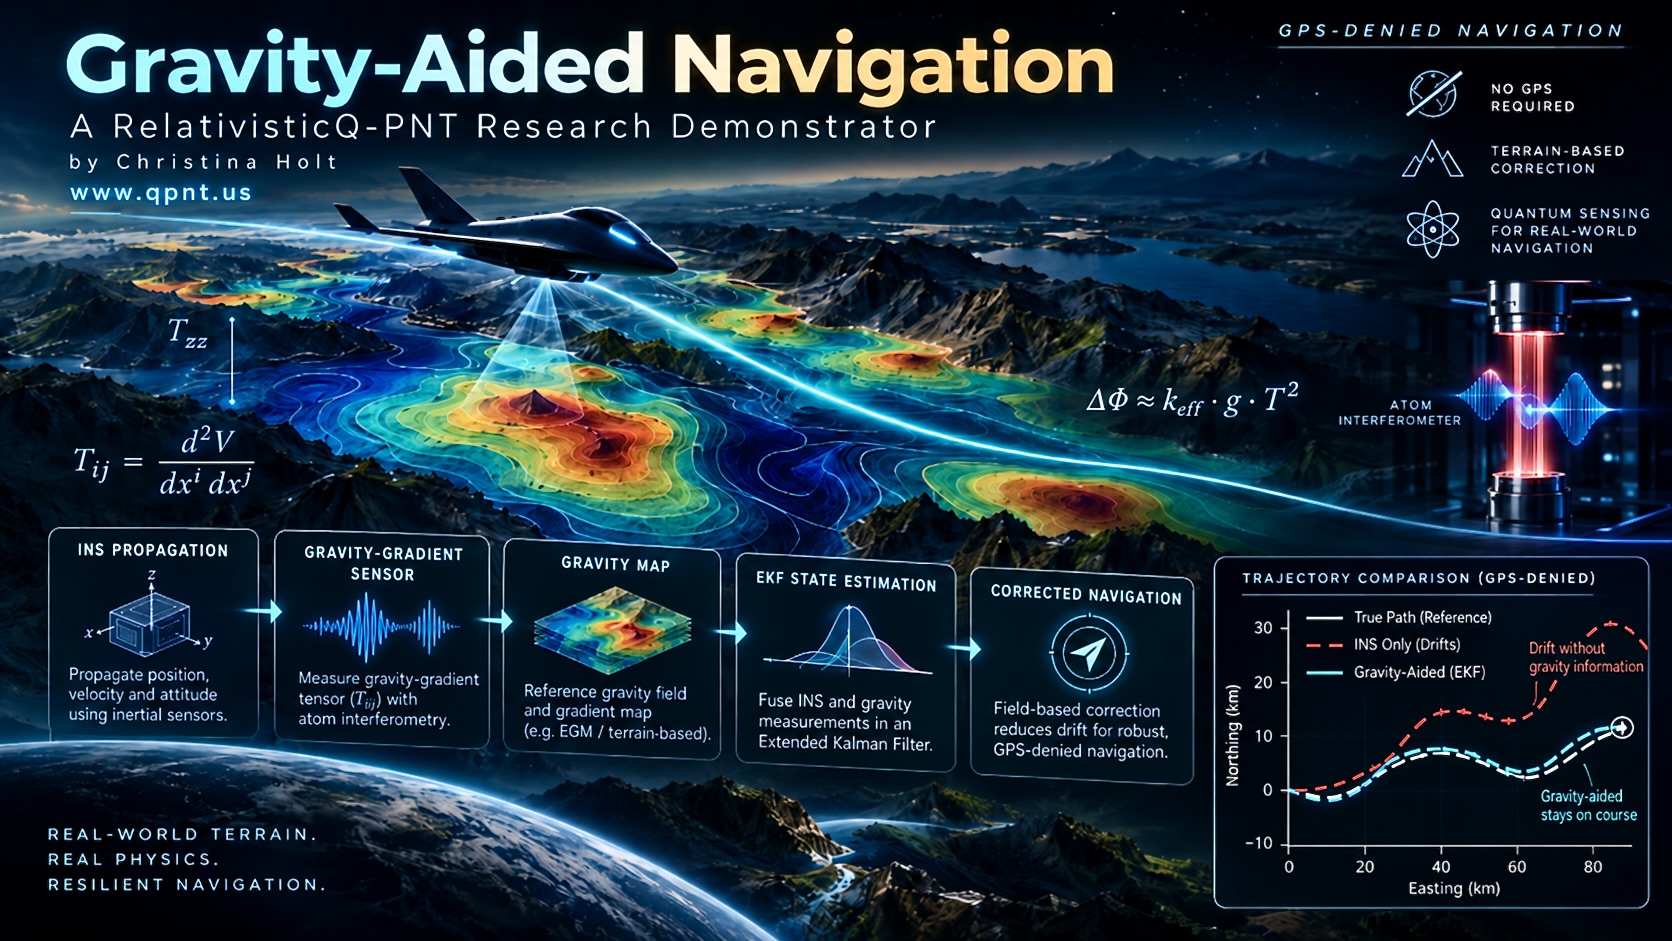
Gravity-Aided Navigation
Mach 0.8 / 50+ km
Simulated GPS-denied cruise
- Challenge
- Inertial navigation accumulates drift when satellite updates are unavailable. The research challenge was to introduce an independent reference during a simulated cruise trajectory.
- Approach
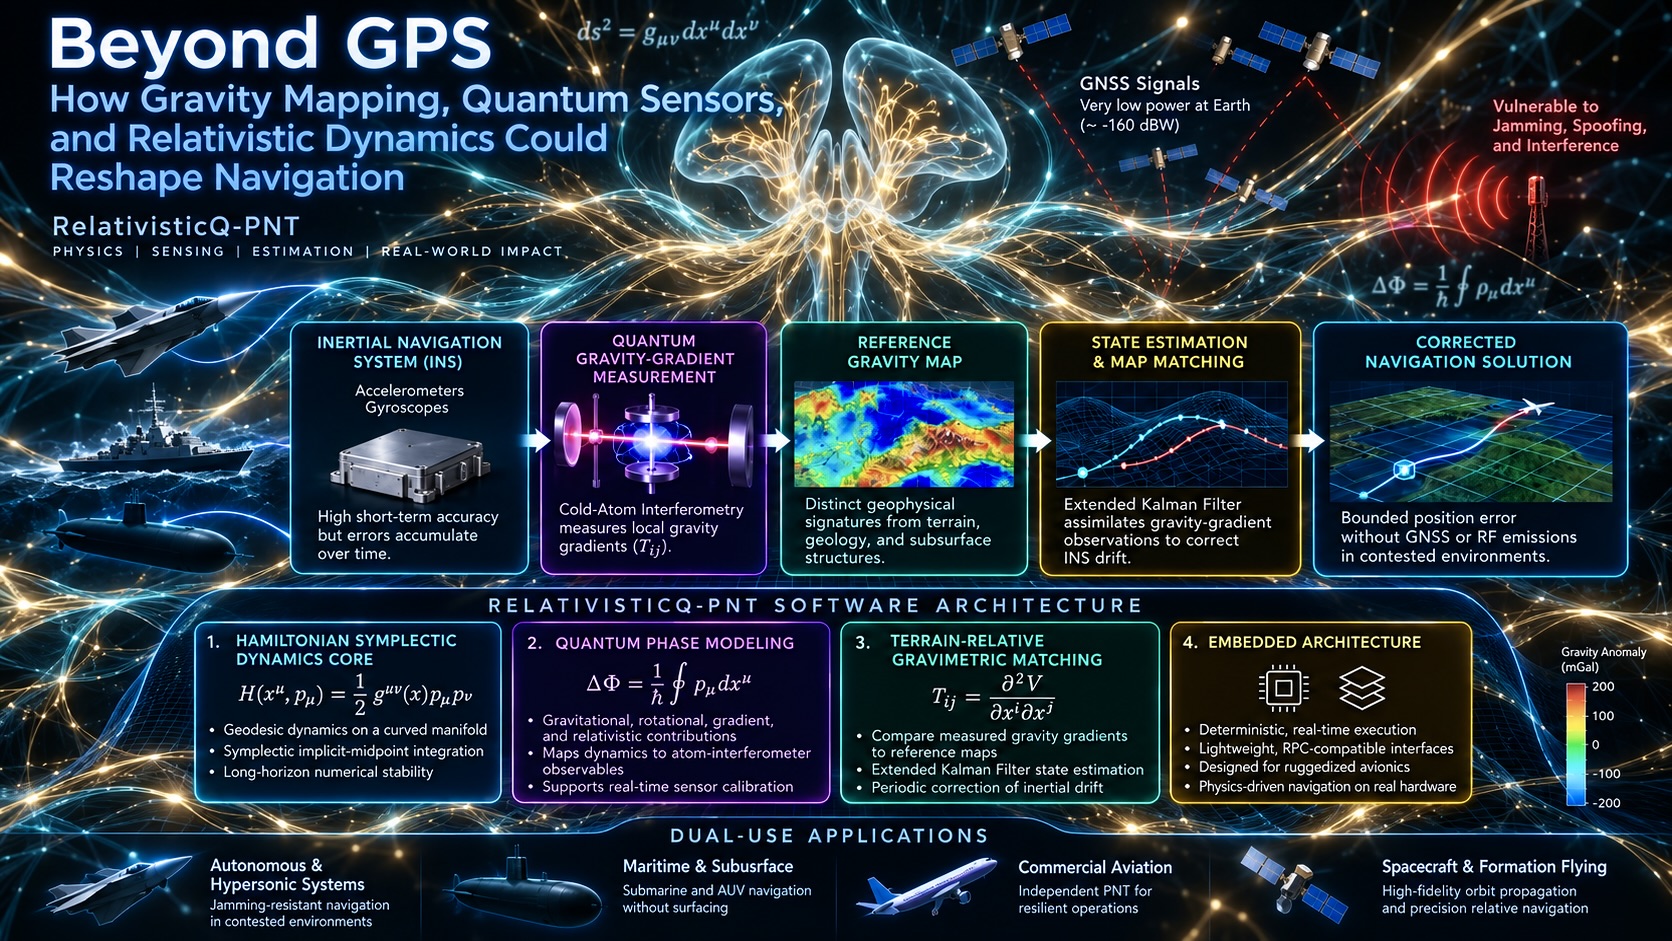
- Relativistic Q-PNT combined inertial propagation with gravity-gradient map observations to provide external corrections to the state estimator.
- Result
- A simulated Mach 0.8 cruise beyond 50 km with GNSS updates denied demonstrated gravity-gradient corrections alongside the drifting unaided inertial solution.
No quantified reduction in RMS or terminal position error is reported here. Realistic sensor noise, map uncertainty, and hardware validation remain important next benchmarks.